Engineering portfolio
Nir Herscovici
Engineering leadership across software, sensing and control
Nir Herscovici is a principal engineer and R&D leader with more than a decade of experience developing integrated hardware and software for aerospace manufacturing. His background in mechanical engineering and computer science connects algorithm development with instrumentation, electromechanical design and control.
At Precision Castparts, he built and led a 22-person multidisciplinary R&D organization, managed a seven-figure R&D budget and owned the $5M+ technology scope for a new manufacturing facility. His organization deployed 15+ systems across ten facilities in three countries. He also served as the customer-facing technical lead on an investigation involving nine aerospace OEMs.
His work translates neural-network assessments into operator guidance and equipment interlocks, with defined responses when measurements are unavailable or inconsistent. Electromechanical actuation and feedback control have delivered yield improvements of up to 5%, while equipment-health monitoring supports preventive maintenance. He combines laser metrology with computer vision to measure part geometry, verify alignment and identify defects, giving engineering and operations teams repeatable evidence for critical decisions.
Across participating plants, broader program outcomes included 25%+ fewer recordable safety incidents, 30%+ reductions in scrap and defects, and 10%+ improvements in uptime and throughput.
His technical record includes patented and patent-pending technologies, publications, conference presentations and workshops. His work received LMPC’s 2022 Best Paper and 2024 Most Innovative Work awards.
- 22person R&D team
built and led - 15+systems in continuous
production operation - 10facilities across
three countries - $5M+technology scope
owned and delivered
Head of Manufacturing Technology & Principal Engineer, R&D
Precision Castparts Corp. · 2020–2026
Core capabilities
Engineering leadership
Technical direction, multidisciplinary teams, investment and program delivery, grounded in direct engineering experience.
Explore leadershipSoftware & computing
Python applications, machine learning, geometric algorithms and data processing, from analytical methods to deployed software.
Explore softwareHardware & control
Instrumentation, acquisition interfaces, PLC integration and electromechanical design, supported by physical verification.
Explore integrationTechnical direction & execution
Leadership & delivery
Herscovici set technical roadmaps, managed a seven-figure R&D budget and secured more than $2M in OEM and cross-division funding. He recruited engineers, advised graduate researchers and developed a multidisciplinary organization while remaining involved in software, controls and technical verification.
Team development, program ownership and results
Build engineering capability
He led ten engineers, five graduate researchers and seven technicians, hiring or recruiting seven of the engineers and advising all five researchers. Every engineer earned a promotion; one technician advanced to superintendent. Twelve of fifteen interns joined full time, and the internship structure was adopted company-wide.
Own delivery and investment
He managed a seven-figure R&D budget, presented roadmaps to the COO and secured CEO approval to expand the organization. Capital proposals typically targeted payback below twelve months. He also secured more than $2M in OEM and cross-division funding.
Coordinate complex integration
At a $500M greenfield facility, he owned the $5M+ technology scope, coordinating contractors, the equipment supplier and delivery milestones. Instrumentation for seven furnaces was part of the program from site inception.
Lead customer engineering
He served as technical lead to nine aerospace OEMs, including Pratt & Whitney, GE Aerospace, Rolls-Royce and Lockheed Martin, during a material-defect investigation. He also led image analysis in a DARPA-funded consortium involving four OEMs.
Reported operational results
At participating plants, program outcomes included 30%+ reductions in scrap and defects, 25%+ fewer recordable safety incidents, and 10%+ improvements in uptime and throughput.
Delivery discipline
Business cases and trade studies informed investment. Stage-gate reviews governed progression from pilot to production; weekly schedules and executive roadmaps made progress and dependencies visible. Standard hardware, in-house software and documented procedures established ongoing ownership within the operating teams.
Career progression and milestones
- 2014Manufacturing Process Technology Engineer, R&D. Vision program starts, Univ. of Birmingham
- 2015Research and Data Analytics Engineer, R&D
- 2016First in-house process vision
- 2017Senior Manufacturing Process Technology Engineer. Builds internship program
- 2018Neural-network development begins
- 2019Talk: vision for process control
- 2020Head of Manufacturing Technology and Principal Engineer, R&D. Head of a 22-person R&D organization. First direct engineering hires
- 2021Provisional application, AI process control. Talks: equipment health, ML and vision
- 2022LMPC Best Paper Award. Selected to lead greenfield technology
- 2023$500M greenfield plant breaks ground. Talk: greenfield technology roadmap
- 2024LMPC Most Innovative Work Award
- 2025U.S. patent granted; two more published. Talk: company-wide technology roadmap
- 2026Inspection filing; conference paper
Selected work
Technical case studies
Six studies make his contribution explicit: the problem, what he designed or implemented, the engineering decisions and the resulting evidence.
01 Detection and Tracking with Sparse DataNeural networks screening 30,000 hours of video for rare critical events95% fewer false positives · manual review cut 100× · resolved for all nine OEMs
Problem
A rare contamination event, a few pixels wide and present for only a handful of frames, had to be located across more than 30,000 hours of production video. Glare, flicker and sensor noise produced near-identical signatures, and only 73 confirmed examples existed to learn from. Manual review could not scale, and every finding had to withstand audit by nine aerospace customers.
Solution
A high-recall neural detector screens each frame, a motion tracker confirms genuine events by their physical trajectory, and a data-quality monitor flags footage that falls outside the training distribution. Processing ran on a distributed platform alongside time-aligned process telemetry, so every confirmed event is preserved with its frames, trajectory and process context. The output is a reviewable chain of evidence rather than a list of alarms.
Scope of work
- Role
- Designed and implemented the detection and tracking pipeline; customer-facing technical lead for the investigation.
- Team
- More than 50 contributors across sites and divisions, about 30 of them engineers; weekly review calls with customer executives and specialists.
- Data
- 1,132 production runs, 2,200 videos, 30,000+ hours, about 4 TB, time-aligned with process telemetry.
- Customers
- Nine aerospace OEMs.
- Impact
- 95% fewer false positives at 95%+ confirmed-event recall; manual review cut 100×; projected review cost down about 80%; the defect was resolved for all nine OEMs.
Technical details
Engineering challenge
Contamination events involved targets only a few pixels across, visible for a handful of frames. Glare, flicker, and sensor noise produced similar observations. Only 73 confirmed examples were available, camera conditions varied, and each reported event required evidence suitable for customer review.
Architecture and decisions
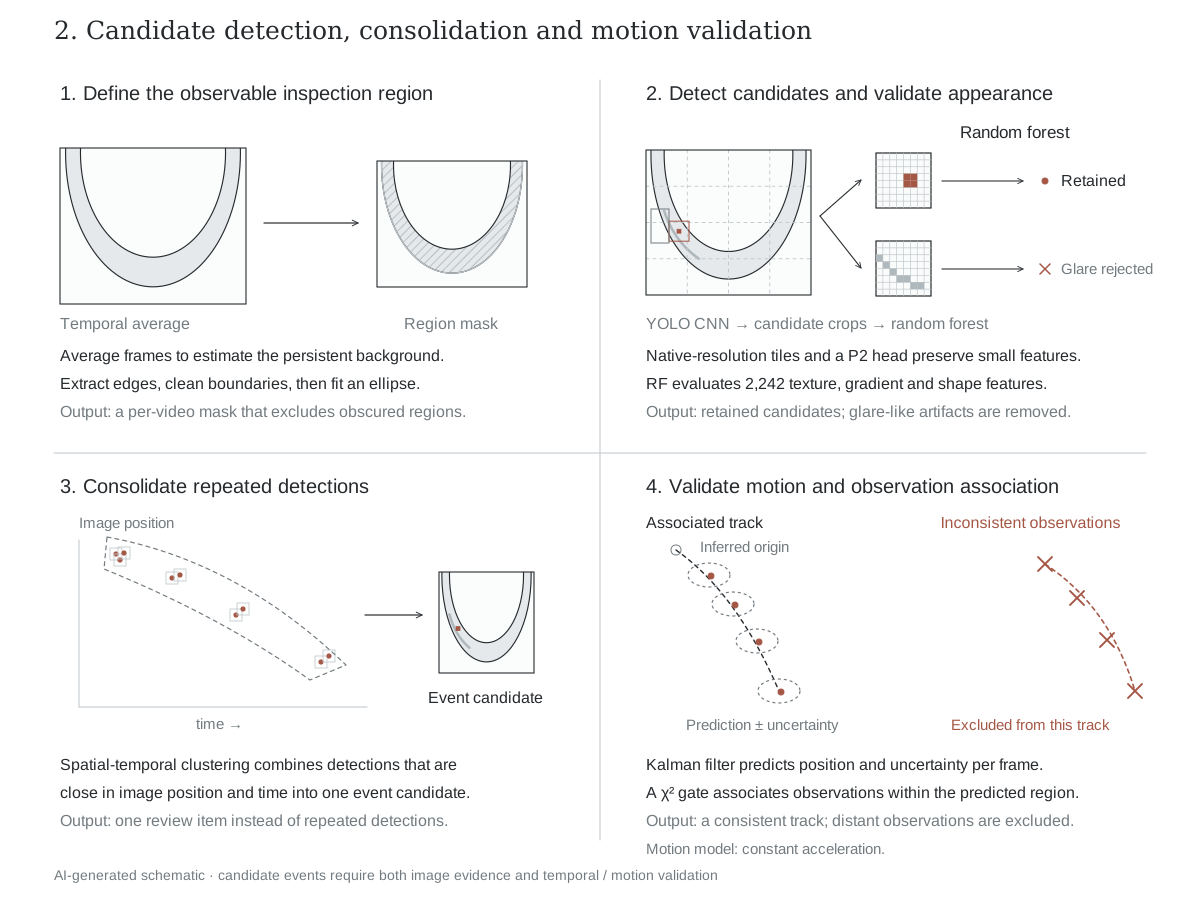
- Preserve small targets. A tiled detector with a high-resolution detection head retained image detail. Restricting analysis to the physically relevant region reduced irrelevant candidates.
- Combine appearance with motion. A high-recall CNN generated candidates; a random forest, spatial-temporal clustering, and constant-acceleration Kalman tracking tested appearance, continuity, and physical plausibility.
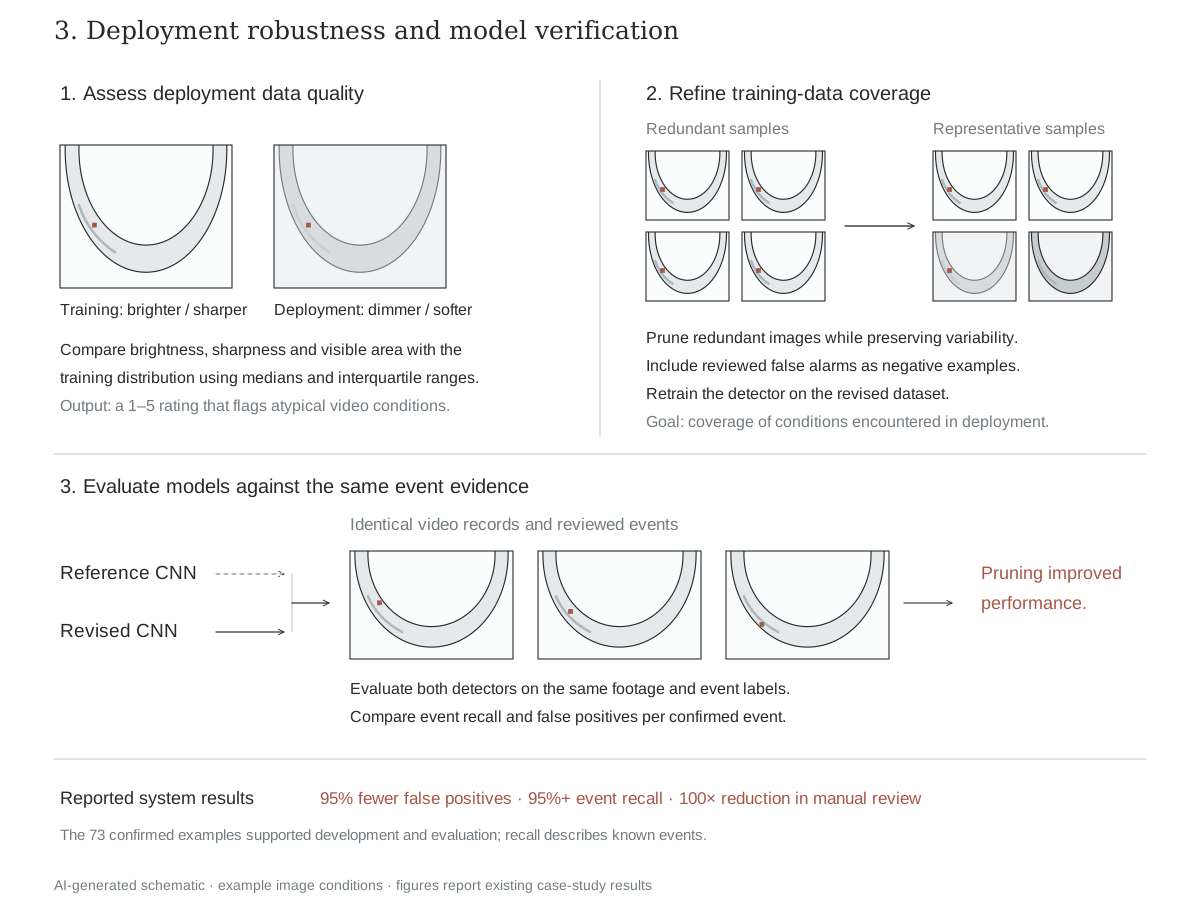
- Evaluate the data as well as the model. Distribution analysis exposed brighter, sharper training images than field recordings. Dataset revision addressed that mismatch, while a monitor flagged unfamiliar video conditions.
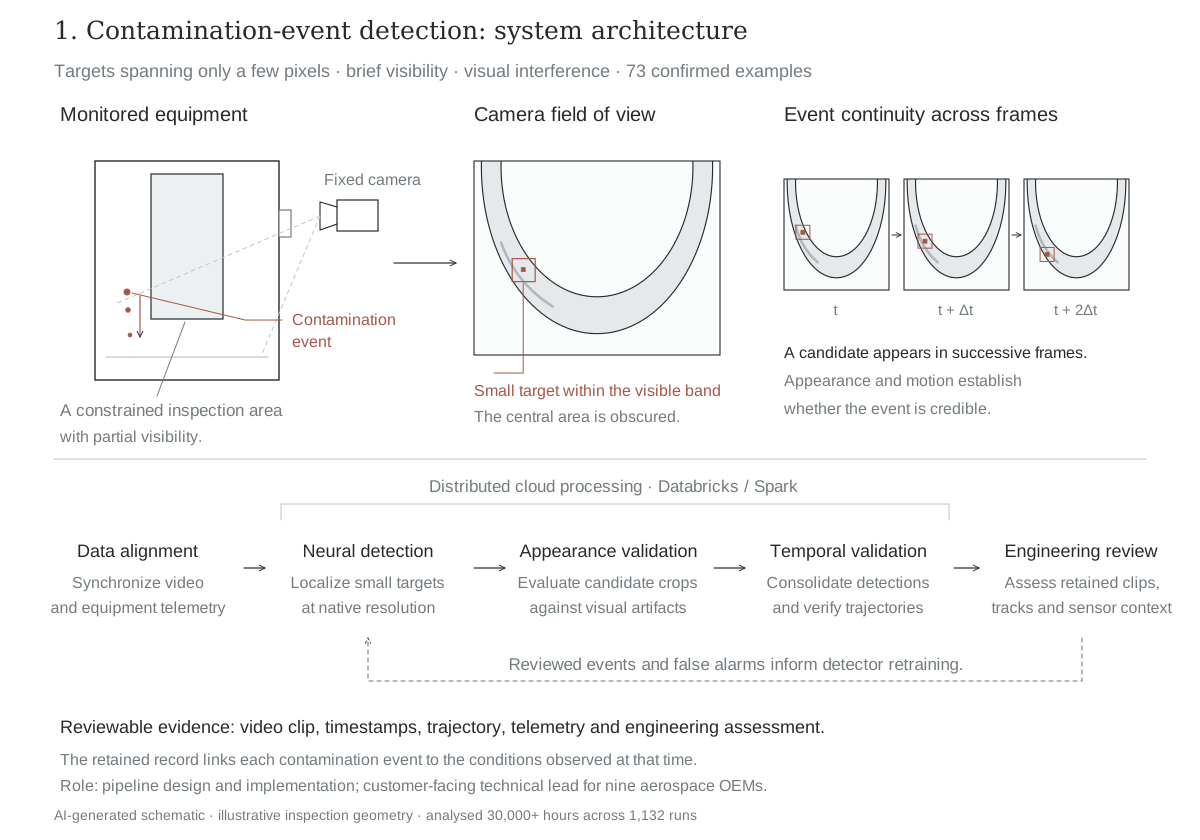
Databricks supported distributed video processing with time-aligned controller telemetry. Timestamps, frames, trajectories, and engineering assessments remained attached to each event, preserving traceability through the review.
Evidence and outcome
The investigation supported resolution of the defect for nine OEMs. Reported evaluation showed 95% fewer false positives at 95%+ confirmed-event recall, reducing manual review 100× and projected review costs by approximately 80%.
All 73 confirmed events were detected, but those examples also informed tracker and clustering calibration. Recall therefore describes confirmed-event evaluation. The distribution monitor identifies unfamiliar conditions. Dataset pruning and revised training coverage improved detector performance.
Algorithm detail and detection constraints
The image-quality monitor compares brightness, sharpness, and region size with the training distribution using median- and IQR-based distances. Feature-space analysis guided removal of near-duplicate bright, sharp images and addition of representative field conditions.
A temporal mean, Sobel and Canny edges, morphology, and ellipse fitting locate the region of interest. The random forest evaluates 2,242 texture, gradient, and shape features. Statistical gating rejects detections inconsistent with the predicted track.
02 Perception, Measurement, and Control InterlocksNeural segmentation tracing part geometry for complianceRating in 5–10 s with an image record · among the systems behind 30%+ less scrap
Problem
Ahead of a critical melting step, weld quality rested on an operator’s eye. Ratings drifted between shifts, no record was kept, and a weld that should have failed could proceed into production. The replacement had to return a repeatable result within seconds under variable lighting and clutter, with a defined response whenever a measurement was unavailable or disputed.
Solution
Two cameras, mounted roughly opposite each other, image the weld; neural networks trace the weld and part boundaries, and geometric analysis converts those boundaries into an explicit five-level rating within seconds. Control authority stays with the plant controller: a missing boundary locks the welder, a failed rating holds the next step, and disagreement with the operator triggers review. Every assessment is retained with its image and part record.
Scope of work
- Role
- Led and implemented the system; co-inventor on its provisional patent; co-author of the related conference paper.
- Timeline
- 2025–2026.
- Integration
- Plant controller (PLC) interlock and manufacturing record (MES); two cameras and lighting mounted on the existing equipment.
- Impact
- Rating in 5–10 seconds with an image record for every assessment; one of the inspection and monitoring systems credited with cutting scrap and defects by more than 30%.
- Validation
- About 85% agreement with an engineer across 27 images mid-development, with differences near the rating boundaries.
Technical details
Engineering challenge
Operators assessed electrode welds visually before melting, with ratings varying between shifts. The replacement needed a repeatable result within seconds despite clutter and variable lighting, a defined response to unavailable measurements, and traceability to the part and operator.
Architecture and decisions
- Separate recognition from assessment. Two segmentation networks identify the weld and electrode boundaries. An ellipse establishes the centre, and radial measurements convert those boundaries into an explicit five-level rating.
- Improve observability. Cameras approximately 180° apart assess complementary sectors, reducing dependence on a single viewpoint.
- Allocate control authority explicitly. The PLC retains the interlock. A missing electrode boundary produces no rating and locks the welder; ratings 4 and 5 block the melt; disagreement with an otherwise acceptable operator rating triggers assessment.
Engineering sketch

Assessment sketch

Control-system identifiers associate both images and ratings with the manufacturing record. The operator’s assessment triggers capture, and the computed result passes to the PLC and manufacturing execution system (MES).
Evidence and outcome
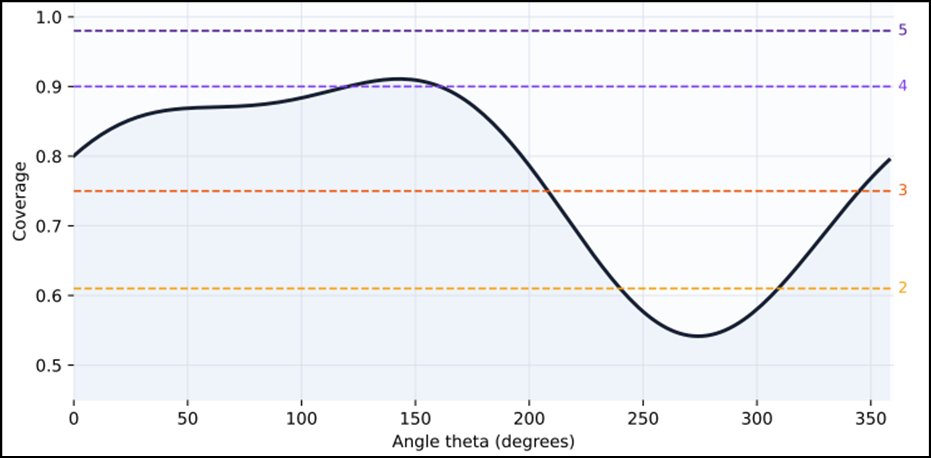
The system returns a geometric assessment in approximately 5–10 seconds and applies explicit acceptance logic with an image record for every assessment. Mid-development agreement with an engineer was approximately 85% across 27 images. Differences clustered near rating boundaries, making threshold calibration a material part of validation.
Measurement geometry and rating thresholds
The ratio shown as “coverage” in the development figures is radial extent, rw(θ)/re(θ). It compares weld and electrode boundaries along each assessed ray. The maximum ratio determines the rating:
Installation, operator interface, and particle analytics

The segmentation outputs also support camera zoom, iris, and focus adjustment. A separate particle-analysis pipeline measures spatter-size distributions for process trending; these measurements do not control the acceptance interlock.
Full-view sketch

Enlarged, with detections


03 Vision Metrology and Cross-Sensor ValidationSensor fusion for robust process measurementGeometry feedback while correction is still possible · laser cross-check on every part
Problem
A forged part can be corrected only while it remains hot, yet the accurate laser measurement was taken after cooling. At the press, operators had no dimensional feedback during the window in which correction was still possible. The glowing surface changes appearance against a cluttered background, so any camera measurement had to be both timely and trustworthy.
Solution
A press-mounted 4K camera measures the glowing part in real time, with neural segmentation isolating the part from tooling before any geometry is fitted. A laser station measures the part again once cold, and both results are linked to the same part record, so each camera reading is validated against the laser reference. Operators act while correction is possible, and the independent measurement confirms the call afterwards.
Scope of work
- Role
- Led and implemented the press-camera system, its measurement method and its integration with the laser scanner built by his organization.
- Timeline
- Laser scanner from about 2020; hot-part camera measurement from about 2022.
- Integration
- PLC-triggered capture; the manufacturing record links camera and laser results by part identifier.
- Impact
- Geometric feedback during forging, with an independent cold reference for every measured part; the laser station also guides cut locations, with operator confirmation.
Technical details
Engineering challenge
Dimensional feedback was needed while a forged billet remained hot enough to correct. The more accurate laser reference measured parts after cooling. At the press, the glowing surface changed appearance against a cluttered background, part dimensions varied, and pixel-level boundary noise affected geometric estimates.
Architecture and decisions
- Match measurement to the decision. A continuously operating 4K camera supplied timely geometry at the press; downstream laser profiles provided an independent reference for evaluating that measurement.
- Isolate the object before measuring it. Semantic segmentation replaced an earlier detector-and-edge approach, separating the billet from tooling and background structures.
- Control noise before fitting geometry. Median filtering smoothed boundary coordinates before least-squares fitting. Development compared 11-, 25-, and 101-sample filter windows.


PLC signals triggered measurement. A common part identifier linked camera observations and subsequent laser scans in the MES, supporting comparison between instruments. Sectional upper- and lower-edge fits characterized the part’s profile; their slope difference measured longitudinal diameter variation.
Evidence and outcome
Operators received geometric feedback during forging, and linked records supported comparison with the cold reference. The laser station also supplied height profiles and cut-location guidance, with operator confirmation before transmission of a cut instruction.
Validation covered matched hot and cold measurements from selected production batches, so the calibration evidence is limited to those evaluated parts.
Measurement model and laser reference
Upper- and lower-edge coordinates are fitted by section using least squares. Their slope difference describes longitudinal diameter variation. The original development notation and 1 mm/m geometric criterion are retained below; they do not establish conventional centreline straightness accuracy.


04 3D Inspection and Condition AssessmentSensor fusion for equipment health assessmentMeasured condition history for every asset · LMPC 2024 Most Innovative Work Award
Problem
Reusable, high-value process vessels wear, sustain damage and accumulate deposits over service. Visual inspection could neither measure the wall nor show how any vessel had changed across its life, so repair and retirement decisions rested on judgement. The internal geometry had to be measured directly, and every measurement tied to the specific asset.
Solution
A telescoping scanner carrying six lasers and cameras maps the internal surface at more than 50,000 points per second. Software computes circularity, taper and local defects, a model flags surface damage, and each result is tied to the vessel’s identity so a condition history accumulates with every inspection. Repair and retirement decisions now rest on measured data instead of visual impression.
Scope of work
- Role
- Implemented the inspection software and the related vision-based control; led the wider program through his organization.
- Scale
- About 80% of final-melt vessels at one plant; more than 50,000 measurement points per second.
- Impact
- A measured condition history per asset, supporting repair, retirement and maintenance decisions instead of visual judgement.
- Recognition
- LMPC 2024 Most Innovative Work Award.
Technical details
Engineering challenge
Visual inspection provided limited dimensional evidence of wear, local damage and accumulated material. The system needed to measure the internal surface, identify local features and retain a condition history for each asset.
Architecture and decisions
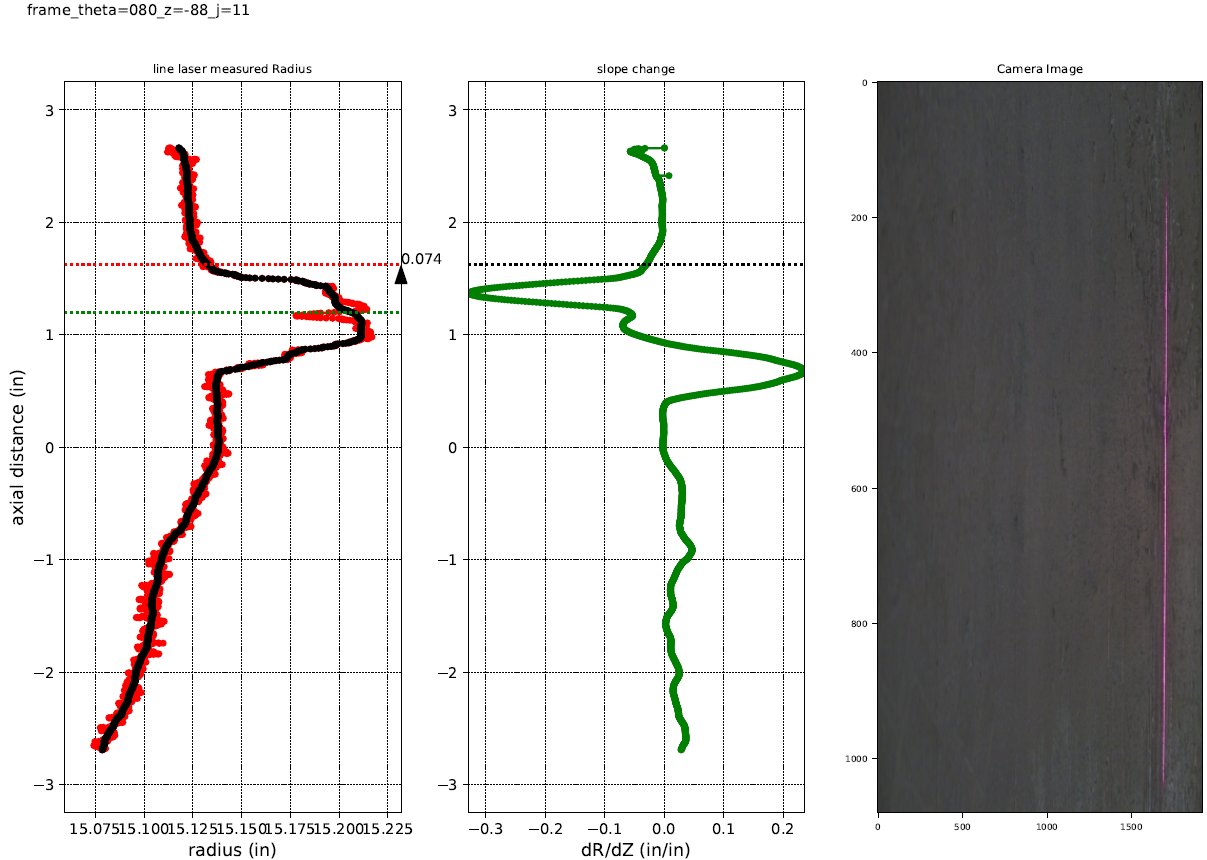
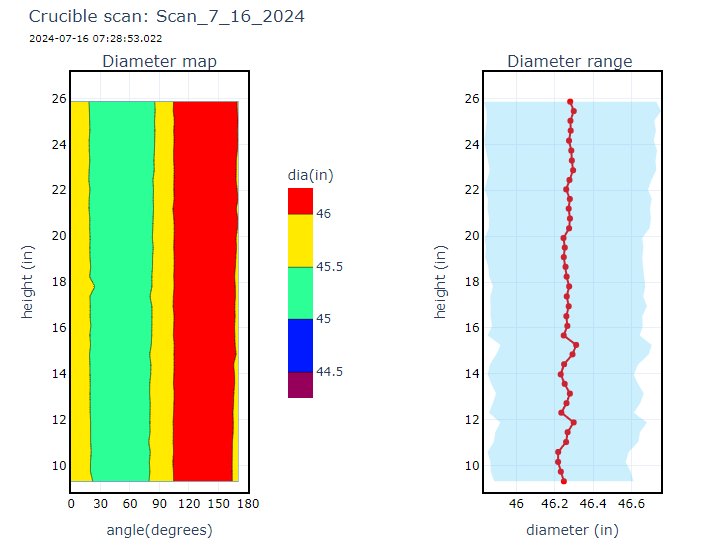
- Capture the geometry directly. A telescoping head carried six lasers at 60° intervals and cameras, acquiring more than 50,000 points per second across height and angle.
- Separate measurement from classification. Geometric analysis calculated circularity, taper and local protrusions or gouges. An ML model flagged surface defects for assessment.
- Preserve asset identity. Inspection records linked measured profiles and condition observations to a crucible identifier, supporting comparison over its service life.
Evidence and outcome
At one plant, inspection covered approximately 80% of final-melt crucibles. The work received the LMPC 2024 Most Innovative Work Award. Coverage describes adoption within that population; acquisition rate describes data throughput, rather than dimensional accuracy.
Related application: geometric measurement for control
Material can accumulate on a crucible wall as a shelf that may later detach. A CNN identifies the region of interest; edge detection locates the crucible, shelf and electrode boundaries.
The mean wall-to-shelf distance, normalized by the wall-to-electrode gap, defines a geometric control input. That measurement informs coil-current adjustments for arc steering. This connects a learned region detector with an explicit measurement and physical actuation.
Related method: US 2025/0277286 A1.
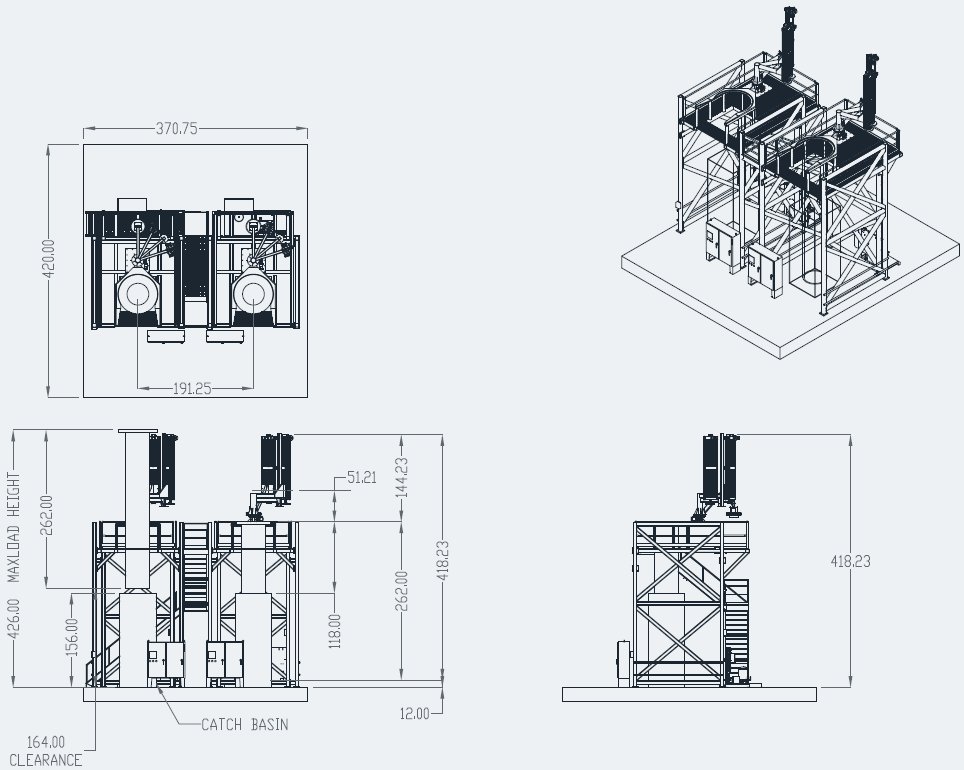
Scanner hardware and representative surface conditions


05 Perception-Assisted Process ControlCustom neural nets for decision support in critical processesPrediction error down 85%+ · intervention within 1 s · LMPC 2022 Best Paper Award
Problem
A melting process must reduce power at a precise point near the end of each run. The visual cue that marks that point is intermittently obscured, and the incumbent system was licensed, hard-wired and dependent on outside specialists for any change. The replacement had to be as reliable as the cue allowed, integrate with the existing controls and remain maintainable by plant engineers.
Solution
A neural network watches for the visual cue while a regression model predicts the point from process data; either can alert the operator, and if no response follows, the system reduces power on its own. Standard cameras, fiber and rack servers with two defined control interfaces replaced the bespoke hardware, and the software is maintained in-house. The same architecture became the foundation for the measurement and monitoring applications that followed.
Scope of work
- Role
- Led the second-generation system from research to production and implemented its software; co-inventor on US 12,332,611 B2.
- Timeline
- Development 2016–2019; in production for more than three years since.
- Impact
- Prediction error down more than 85% over four months of development; automatic intervention within one second of detection; process change qualified with the OEM customer.
- Recognition
- LMPC 2022 Best Paper Award.
Technical details
Engineering challenge
Furnace power must decrease at a defined point near the end of an electrode melt. Visual marker pins indicate that point, but visibility varies. The replacement also had to integrate with existing controls and be maintainable by plant engineers.
Architecture and decisions
- Use complementary observations. A CNN detects marker pins. A regression model independently estimates the trigger position from electrode weight, current and voltage. Each supplies a condition for requesting cutback.
- Define the response sequence. The system alerts the operator with the available evidence. Automatic cutback follows under specified conditions if the operator does not respond.
- Constrain integration and maintenance. Standard cameras, fiber, rack servers and two defined control interfaces replaced bespoke components. Internally maintained software and recorded video supported plant ownership.
Evidence and outcome
Reported prediction error fell more than 85% over four months of development. The system operated in production for more than three years, and the related work received the LMPC 2022 Best Paper Award.
The improvement applies to that development interval. Variable pin visibility remains a constraint; the process-data channel provides a complementary basis for the control decision.
Prediction model and observed visibility conditions
Regression estimates the feed position for cutback from process parameters. The logical OR below identifies a trigger condition; operator notification and the configured response sequence still govern the resulting action.


Legacy system and the integration trade-off
The earlier system used licensed software and a hard-wired control connection. Parameter changes required outside specialists and production downtime. The in-house architecture reduced those dependencies and became a foundation for later measurement and monitoring applications.

06 Electromechanical Design and Feedback ControlElectromechanical systems that raise product yieldClosed a ~2% yield gap between two plants · 19+ products at the highest surface rating
Problem
One plant’s product carried a rougher surface and a lower yield than its sister plant. Steering the arc with a magnetic field would close the gap, but the existing equipment left no room for a single moving coil to reach the top of the melt, and adopting the sister plant’s design would have required structural changes.
Solution
Two coils, one rising with the process zone and one fixed at the top, are driven through power electronics by the plant controller, with camera analysis confirming that the arc rotates as intended. Electromagnetic and flow simulation set the coil geometry, a bench rig proved the coils, drives and control logic, and the assembly was retrofitted to production equipment. Camera-measured arc rotation, rather than coil current alone, served as proof of the intended effect.
Scope of work
- Role
- Led electromagnetic design, controls and verification; implemented the control software; inventor on US 2025/0119992 A1.
- Work
- Electromagnetic and flow simulation, bench rig, drive electronics, PLC control, camera-based verification, production retrofit.
- Impact
- Closed an approximately 2% yield gap between the two plants; more than 19 products at the highest surface rating.
Technical details
Engineering challenge
The field had to follow a rising process zone while fitting existing furnace geometry. A single moving coil could not reach the upper region, and transferring another plant’s design would have required structural changes.
Architecture and decisions
- Split the operating envelope. A moving coil follows the arc zone; a stationary coil covers the top of the melt. The arrangement fits the existing equipment at the cost of a carriage and a second drive.
- Connect models to hardware. COMSOL electromagnetic and CFD models informed coil geometry. A bench rig supported coil, drive and PLC development before furnace trials.
- Verify the physical response. Camera analysis measured arc rotation. Coil current alone was not treated as proof of the intended process effect.
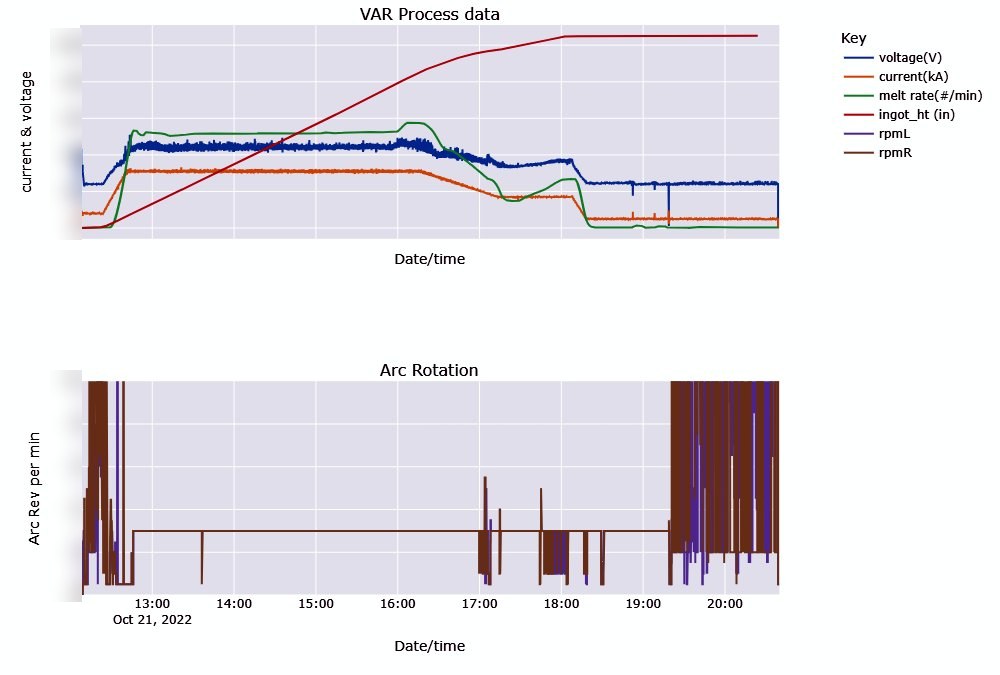
Three opposing segment pairs receive sinusoidal currents separated by 120°. The PLC commands the PWM H-bridges and carriage drive, using current feedback, an encoder and limit switches. Carriage position follows ingot height estimated from weight.
Evidence and outcome
Furnace trials established operating settings; video confirmed arc rotation. Production results reported closure of an approximately 2% interplant yield gap and more than 19 ingots at the highest surface rating.
The surface observations came from one furnace, and the plants differed in respects beyond arc steering. The excitation equation describes the intended current relationship, rather than a measured spatial field map.
Excitation model, installed hardware and process evidence


Representative surface results


Architecture & assurance
From one system to repeatable deployment
Herscovici connected instrumentation, computational methods and equipment control through defined interfaces. Python-based applications, PLC integration and electromechanical hardware formed systems that could be verified, maintained and deployed across facilities.
Architecture, verification and deployment footprint
Integrated hardware, software & control
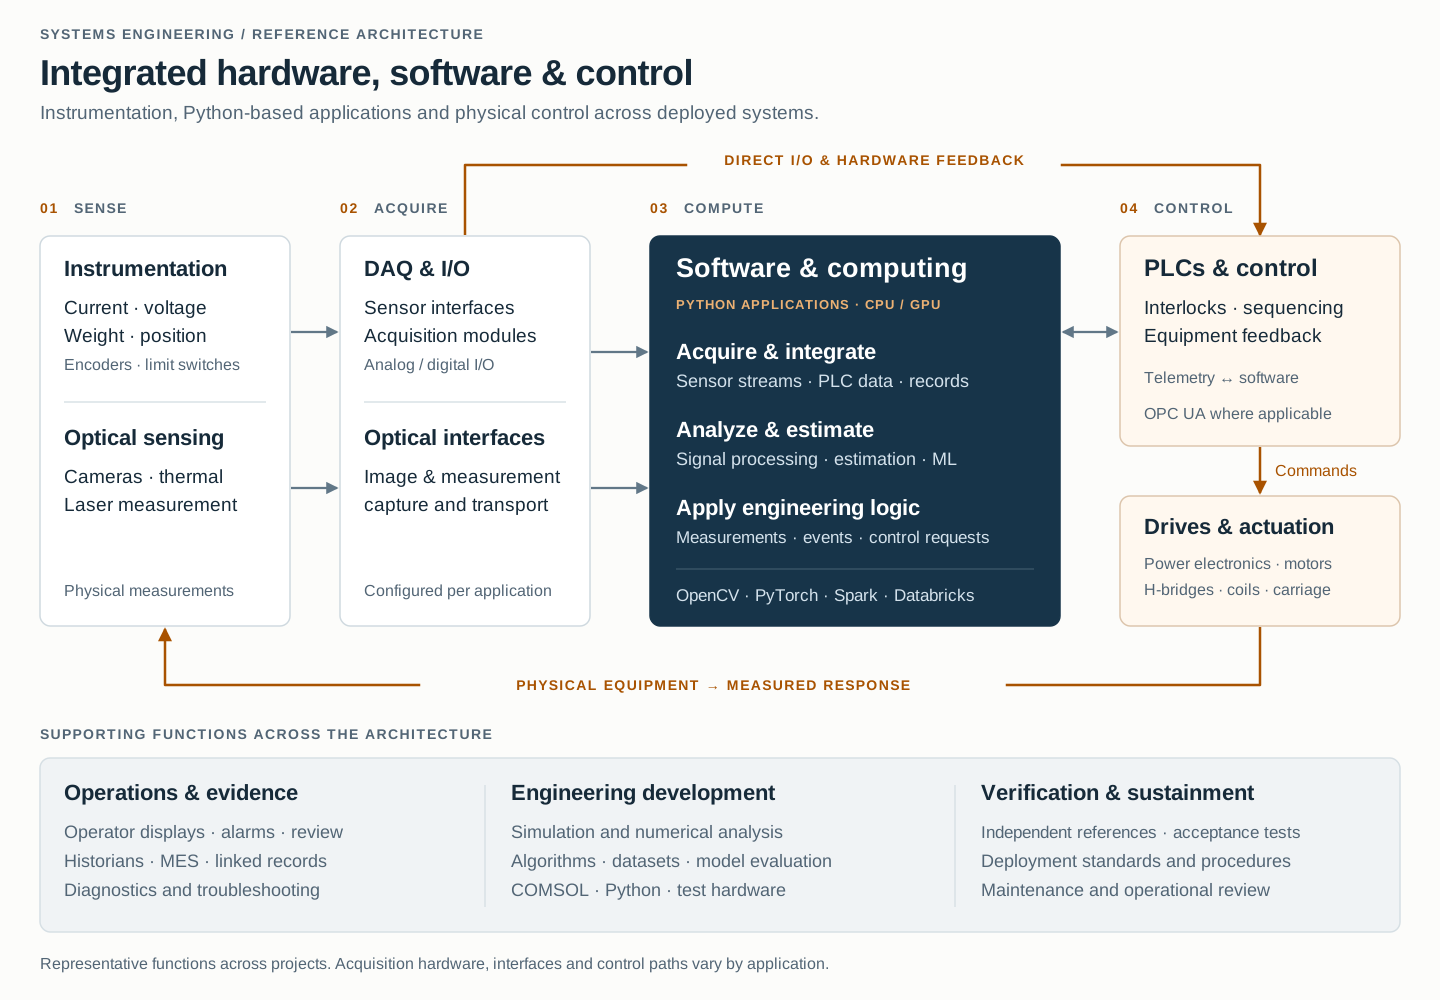
OPC UA connected applicable software services to PLCs; historians and MES associated results with operating records.
Engineering principles
- Define authority and failure behavior. PLCs retained process interlocks and hardware control. Each application defined when software outputs informed operators, requested action or blocked progression.
- Separate recognition from measurement. Neural networks located features; deterministic geometry calculated dimensions and ratings, keeping the measurement logic inspectable.
- Verify against independent evidence. Evaluation used injected events, camera-to-laser comparisons and engineering judgments. FMEA, hazard analysis, acceptance testing and offline model validation preceded deployment; runtime monitoring and incident response supported operation.
- Design for the environment. Installations accommodated heat, arc light, particulate, vibration, vacuum interfaces, electrical noise and cable runs of 100–300 metres.
Reuse the architecture; validate each application
Common hardware, drawings, software and procedures supported deployment across ten facilities. Site-specific work addressed mounting, thresholds, displays and process logic. Capabilities were proven at an operating site before adoption into the shared standard.
The installed infrastructure included 150 cameras, 20 thermal imagers and 35 laser systems, with more than 25 shielded, water-cooled housings behind vacuum-rated viewports.
Deployment footprint
- 1Henderson, NV Mold inspection · flatness measurement · alignment
- 2Wyman-Gordon, Houston, TX Sheet inspection · bar inspection
- 3Huntington, WV Mold inspection · magnetic arc control
- 4Ravenswood, WV Mold inspection · magnetic arc control · flatness measurement · alignment
- 5Toronto, OH Sheet inspection · bar inspection
- 6Morgantown, PA Mold inspection · magnetic arc control · flatness measurement
- 7New Hartford, NY Mold inspection · magnetic arc control
- 8Swansea, UK Sheet inspection · bar inspection
- 9Witton, UK Mold inspection · flatness measurement
- 10Savoie, France Mold inspection · magnetic arc control · flatness measurement
Experience & recognition
A background across mechanical engineering and computer science, supported by patents, publications and more than a decade of technical progression.
Patents, publications and awards
- US 12,332,611 B2Video analysis-based algorithm for triggering power cutback in vacuum arc remeltingGranted June 17, 2025
- US 2025/0277286 A1Shelf detection and control for vacuum arc remeltingPublished Sept. 4, 2025, pending
- US 2025/0119992 A1Twin coil arc sweep system for vacuum arc remelting furnacesPublished April 10, 2025, pending
- U.S. applicationVideo-based algorithm for feature detection and image suitability assessment for VAR meltingPending
- ProvisionalSystem and method for comprehensive weld quality assessment and melt monitoring in vacuum arc remeltingApplication filed
- LMPC 2022Power Update During Vacuum Arc Remelting Using Vision Systems (A. D. Patel, N. Herscovici)Best Paper Award
- LMPC 2024Laser mold-inspection systemMost Innovative Work Award
- PCC Tech. Conf.Vision-based weld quality and melt monitoring system (with K. Schwind)Paper, 2026
Titles are reproduced as filed. Patents are assigned to a Precision Castparts subsidiary. Herscovici served on the Liquid Metal Processing & Casting Conference committee and led annual machine-learning and computer-vision workshops at PCC.
Career, education and technical tools
Roles at Precision Castparts Corp.
- 2020–2026Head of Manufacturing Technology and Principal Engineer, R&D
- 2017–2020Senior Manufacturing Process Technology Engineer
- 2015–2017Research and Data Analytics Engineer, R&D
- 2014–2015Manufacturing Process Technology Engineer, R&D
Education
M.S. Mechanical Engineering · B.S. Mechanical Engineering · B.S. Computer Science
University of Nevada, Las Vegas
Technical tools
- Perception and MLPython, PyTorch, TensorFlow, OpenCV, scikit-learn
- Inference and deploymentONNX, TensorRT, GPU servers, edge devices
- Data at scaleDatabricks, Spark, MLflow, Azure
- Controls and integrationAllen-Bradley PLCs, OPC-UA, Ignition HMI, AVEVA MES
- Design and simulationSolidWorks, COMSOL, MATLAB, Simulink
Earlier production work included C/C++ and CUDA; recent development centered on Python.